The project
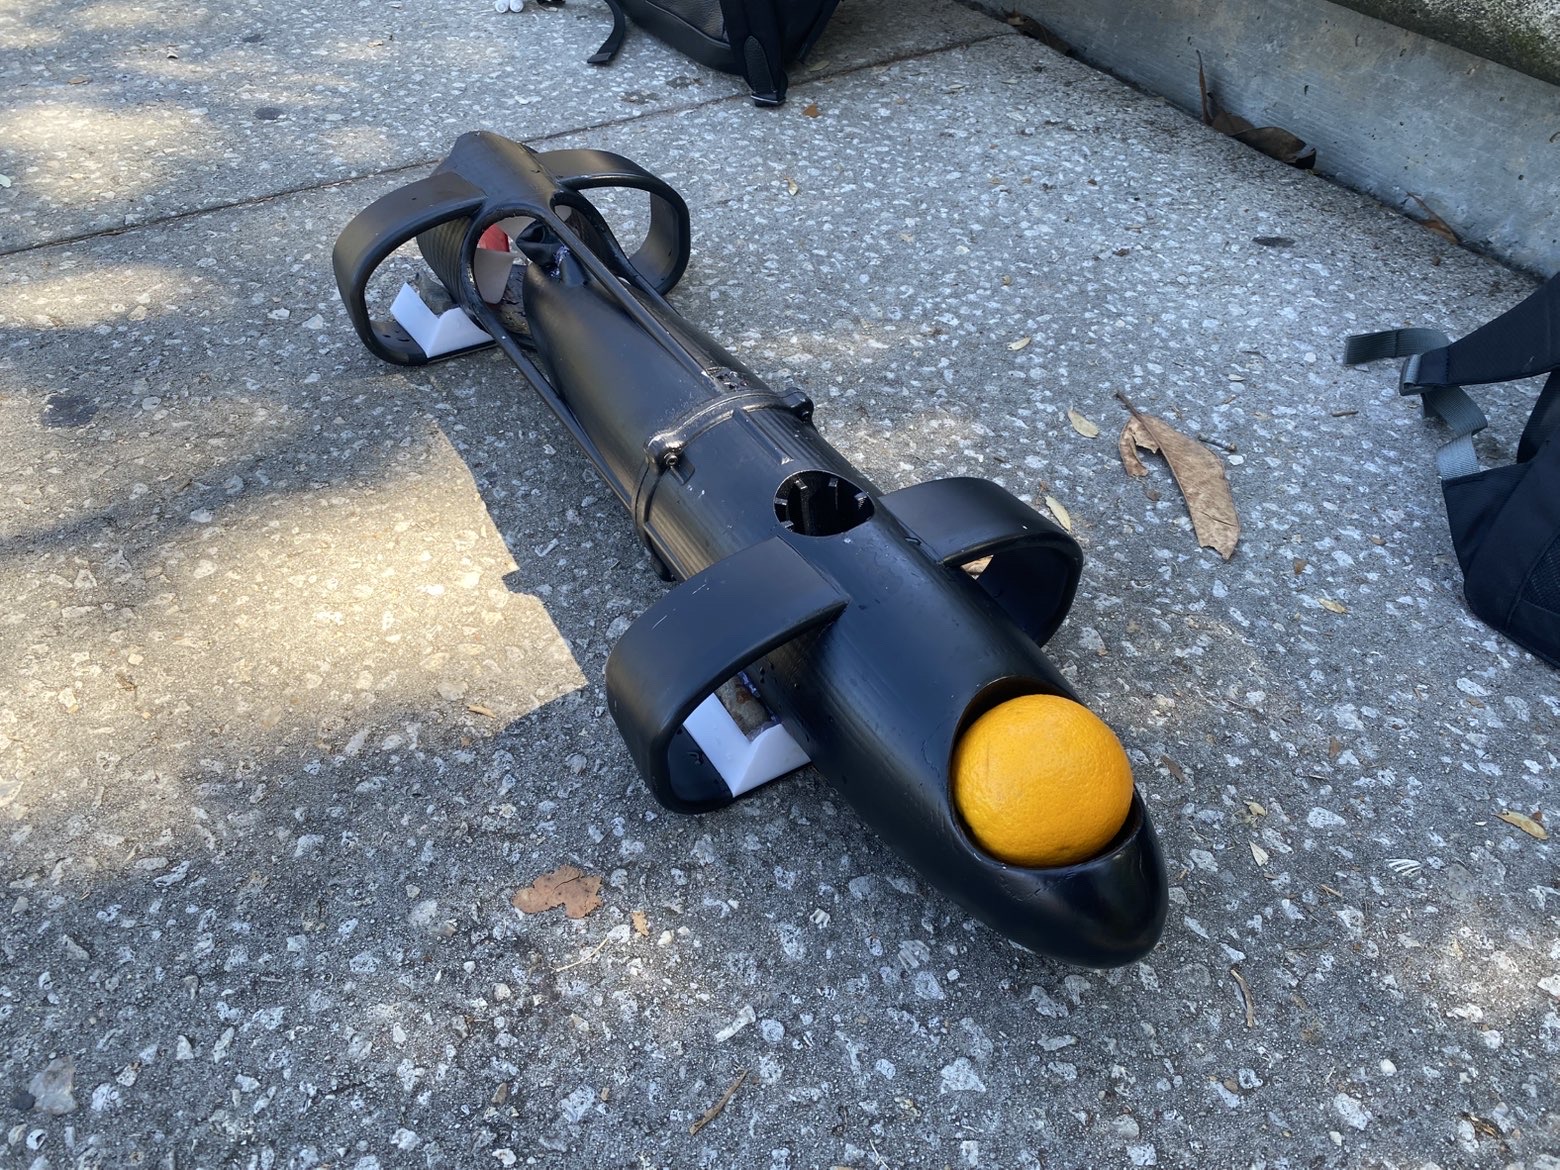
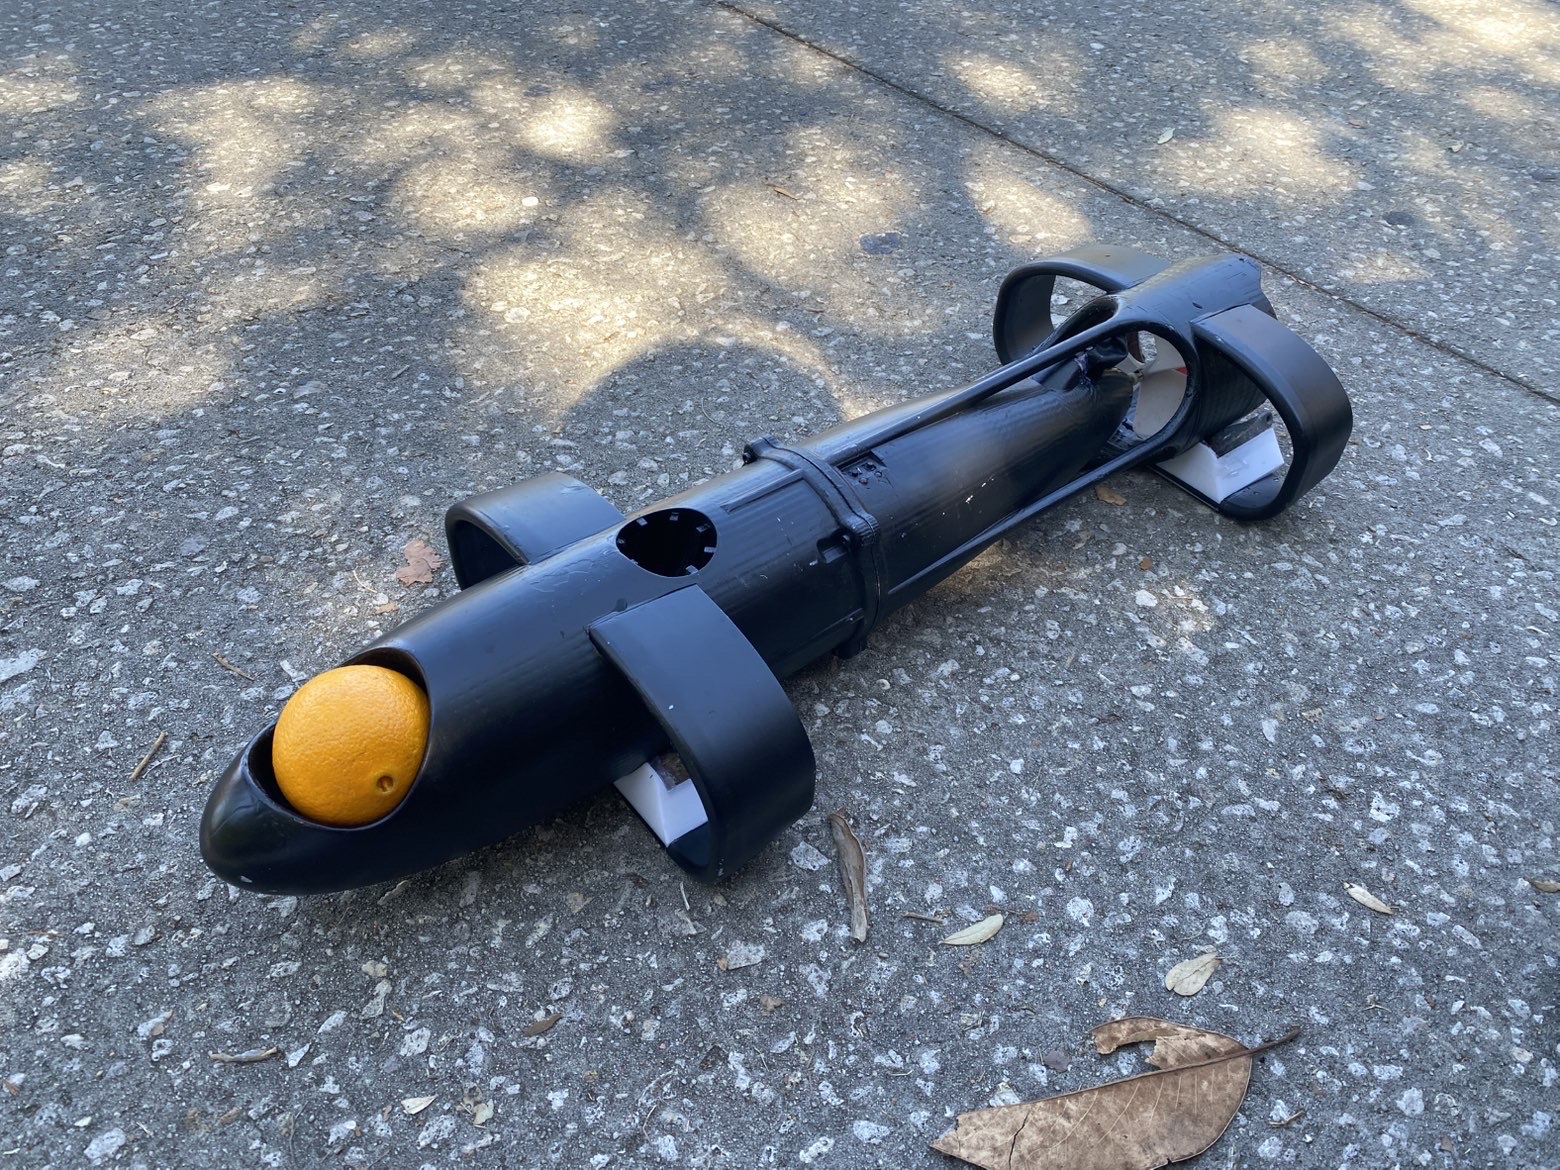
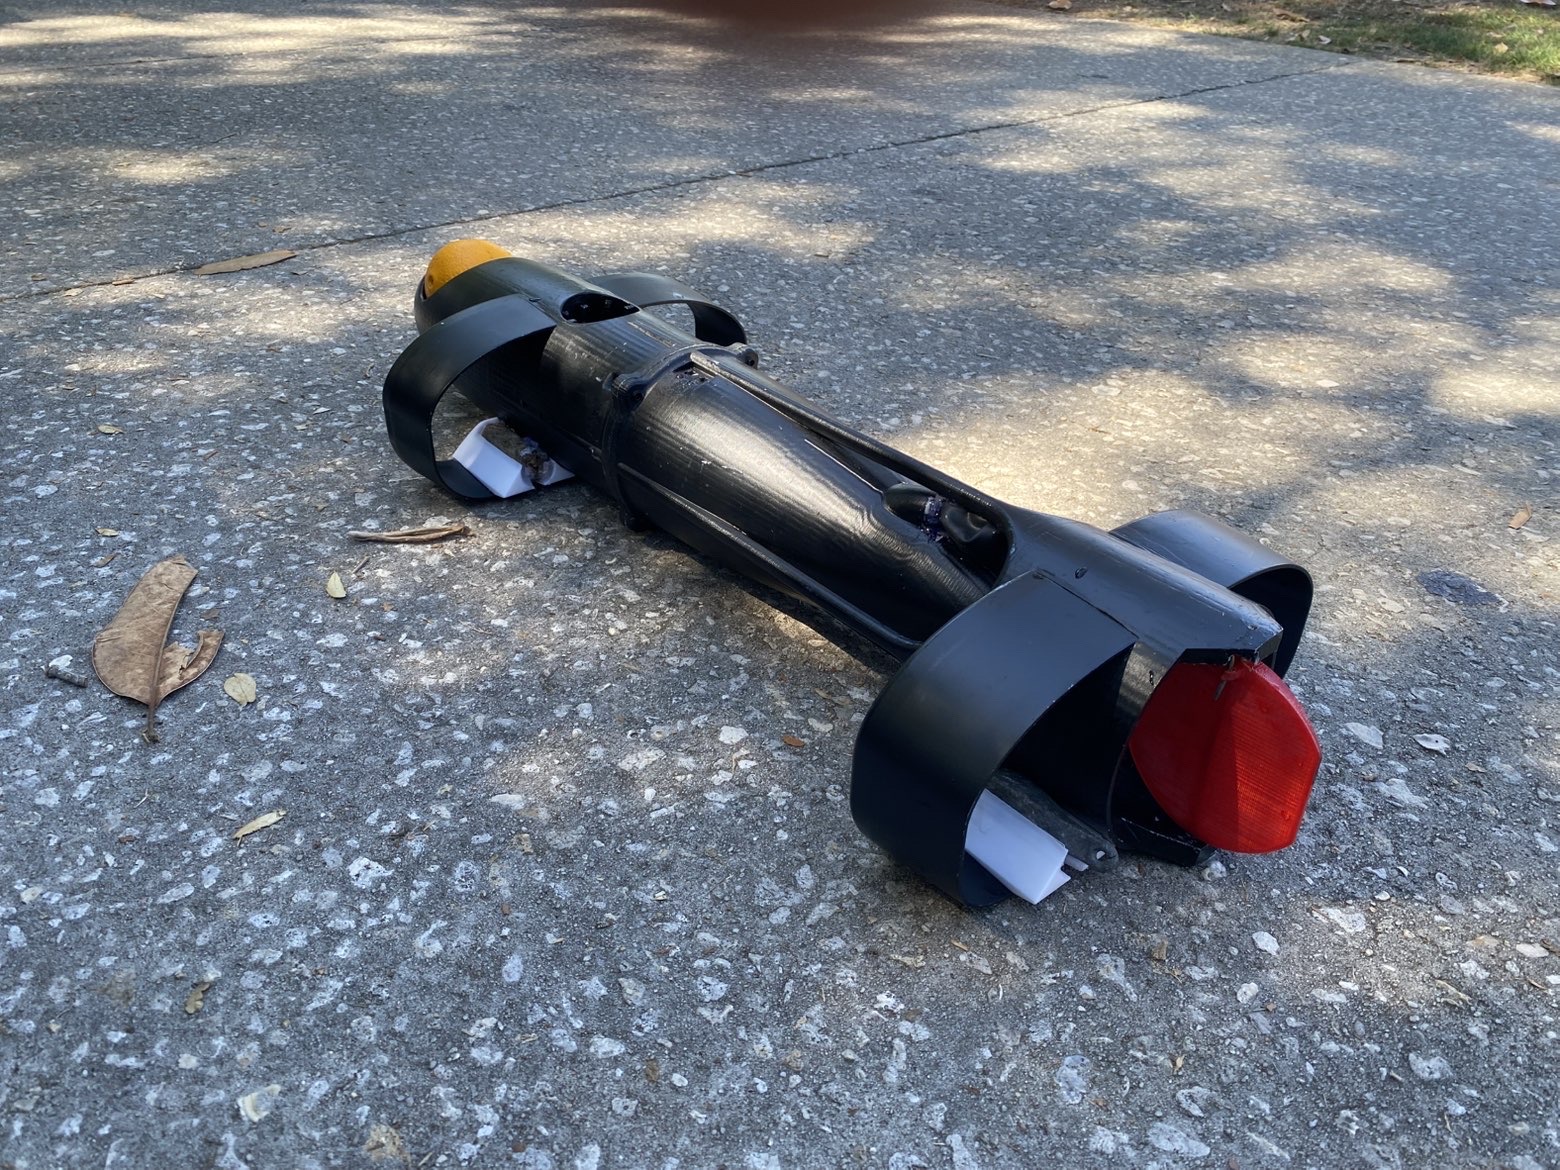
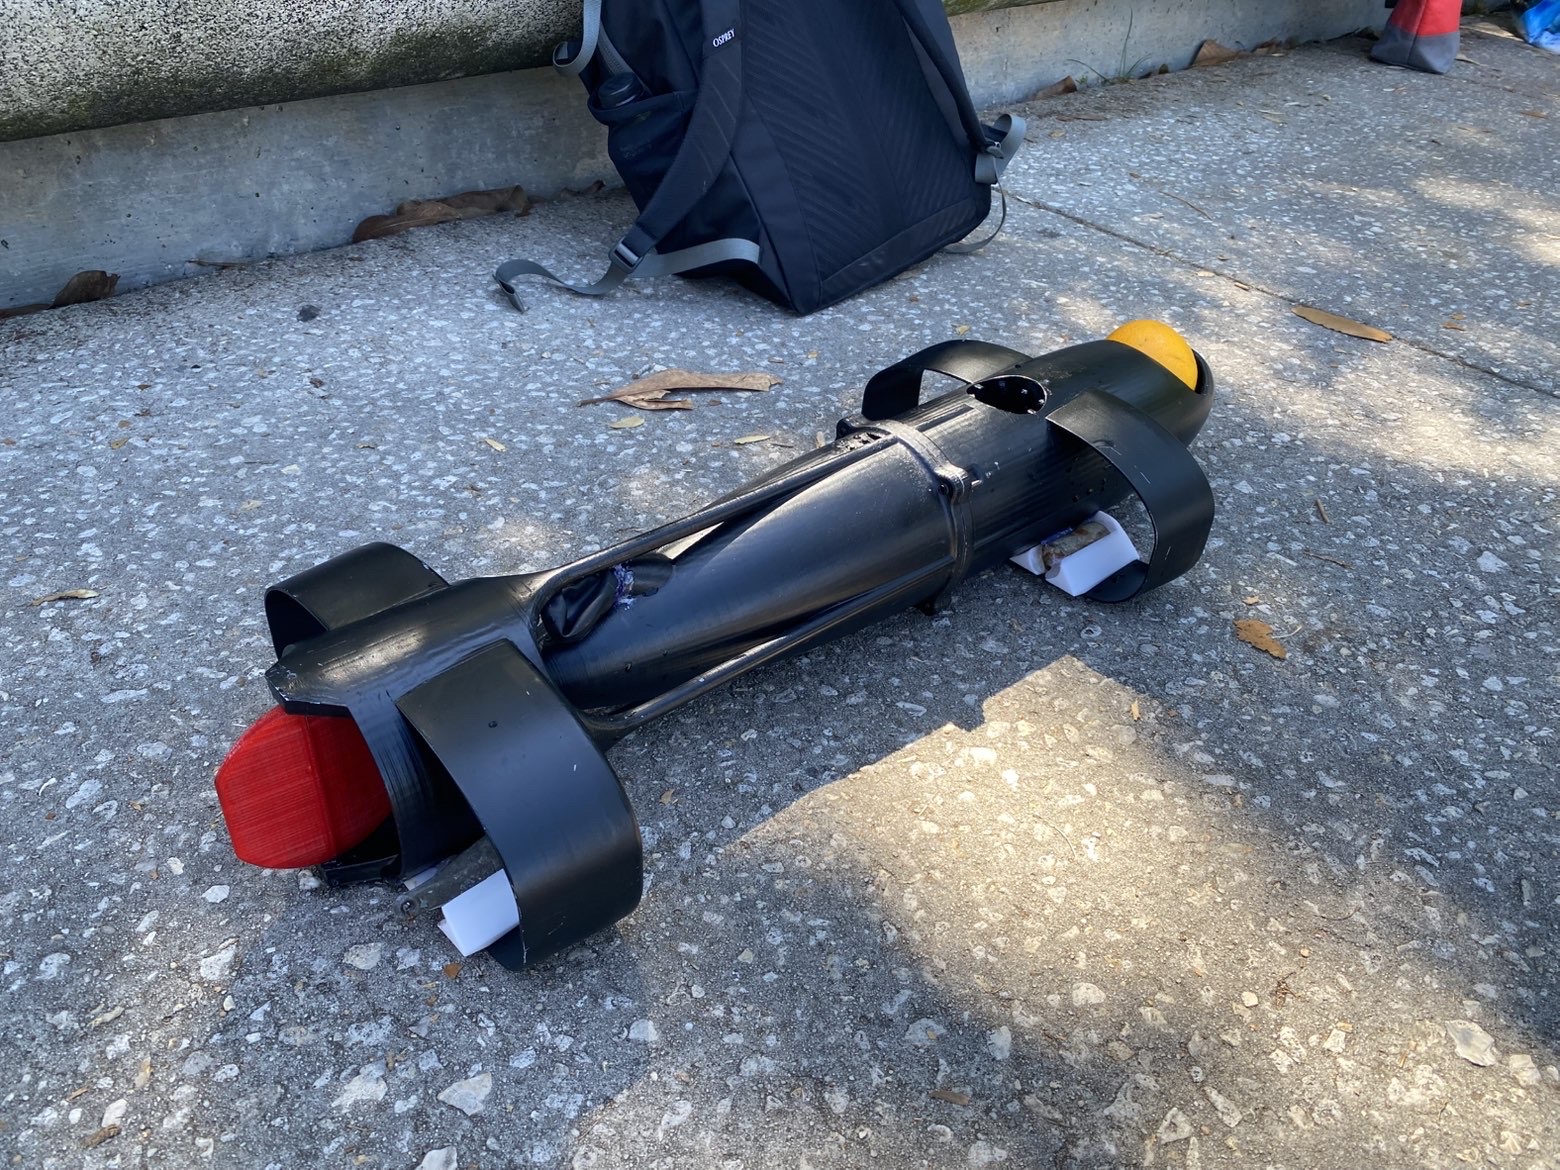
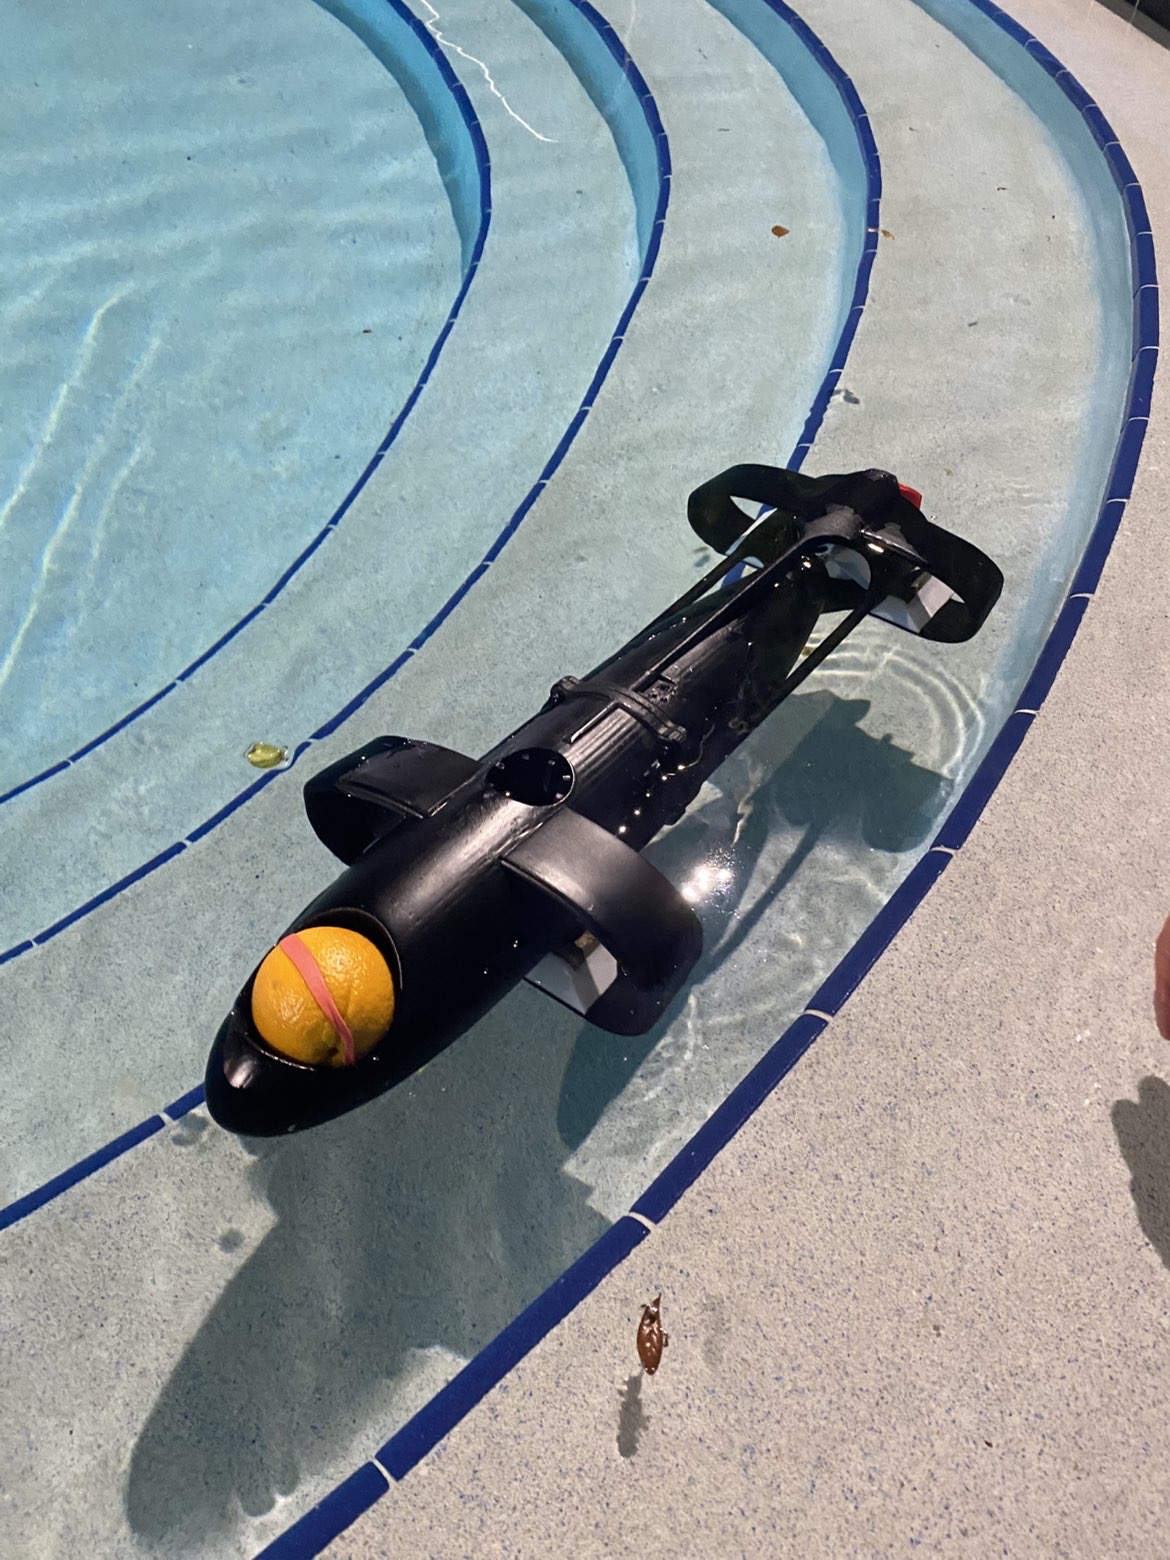
Working in a four-person team, I helped develop an autonomous submersible. My contributions covered hull and component layout, a vertical-thrust approach to depth control, Arduino programming, and electromechanical assembly.
ROBOTICS / ELECTROMECHANICAL
A four-person submersible project integrating hull design, active depth control, and untethered mission logic.
Working in a four-person team, I helped develop an autonomous submersible. My contributions covered hull and component layout, a vertical-thrust approach to depth control, Arduino programming, and electromechanical assembly.
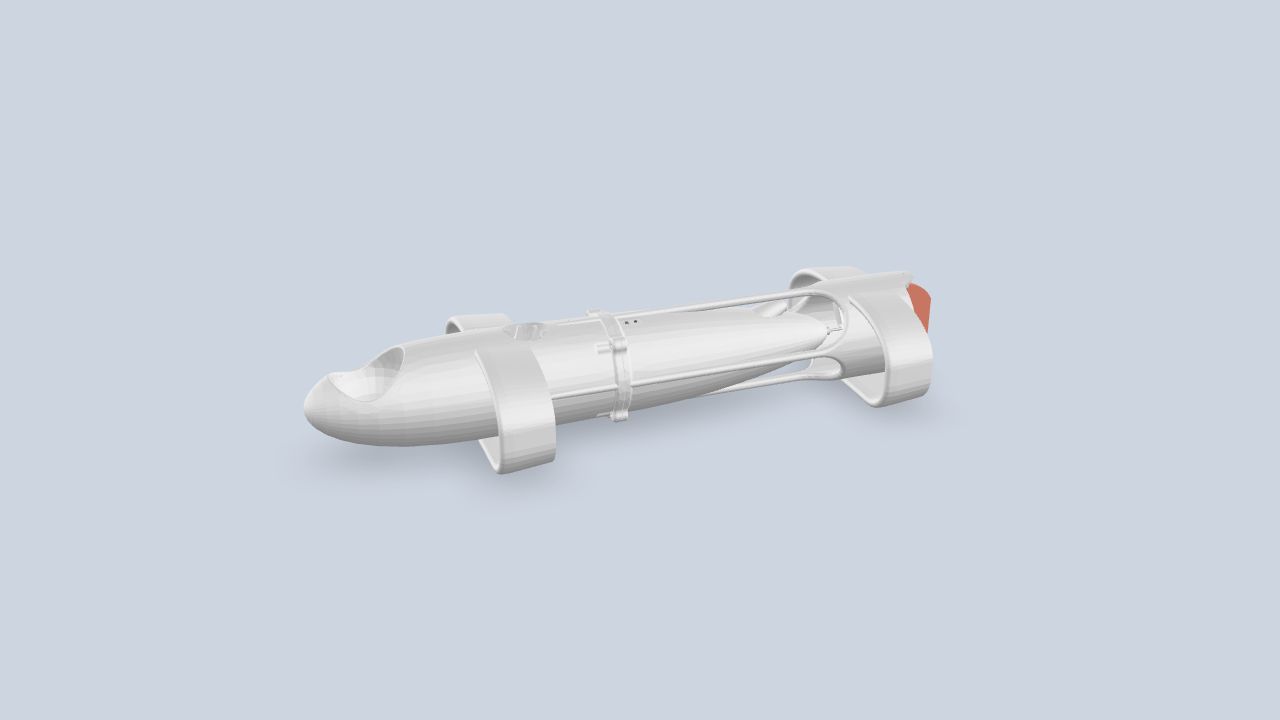
Used Fusion 360 and SOLIDWORKS to model the hull with attention to fluid dynamics and internal component fit.
Integrated a dedicated vertical thrust motor to provide active depth adjustment and support stable operation.
Programmed Arduino C++ logic for untethered missions and worked on custom wire fabrication and waterproofing the drivetrain shafts.
CAD ASSEMBLY
PROJECT GALLERY
Select any image to view it at full size.
STATUS & EVIDENCE
The project brought CAD, embedded programming, and physical assembly into one team-built system. Quantitative depth accuracy and endurance results are not yet included in this portfolio.
KEEP EXPLORING